
ROS 2 & Robot Software Architecture (Fundamentals) · Lesson 09
Launch Files
Est. 50–70 min
Why
Why this lesson matters
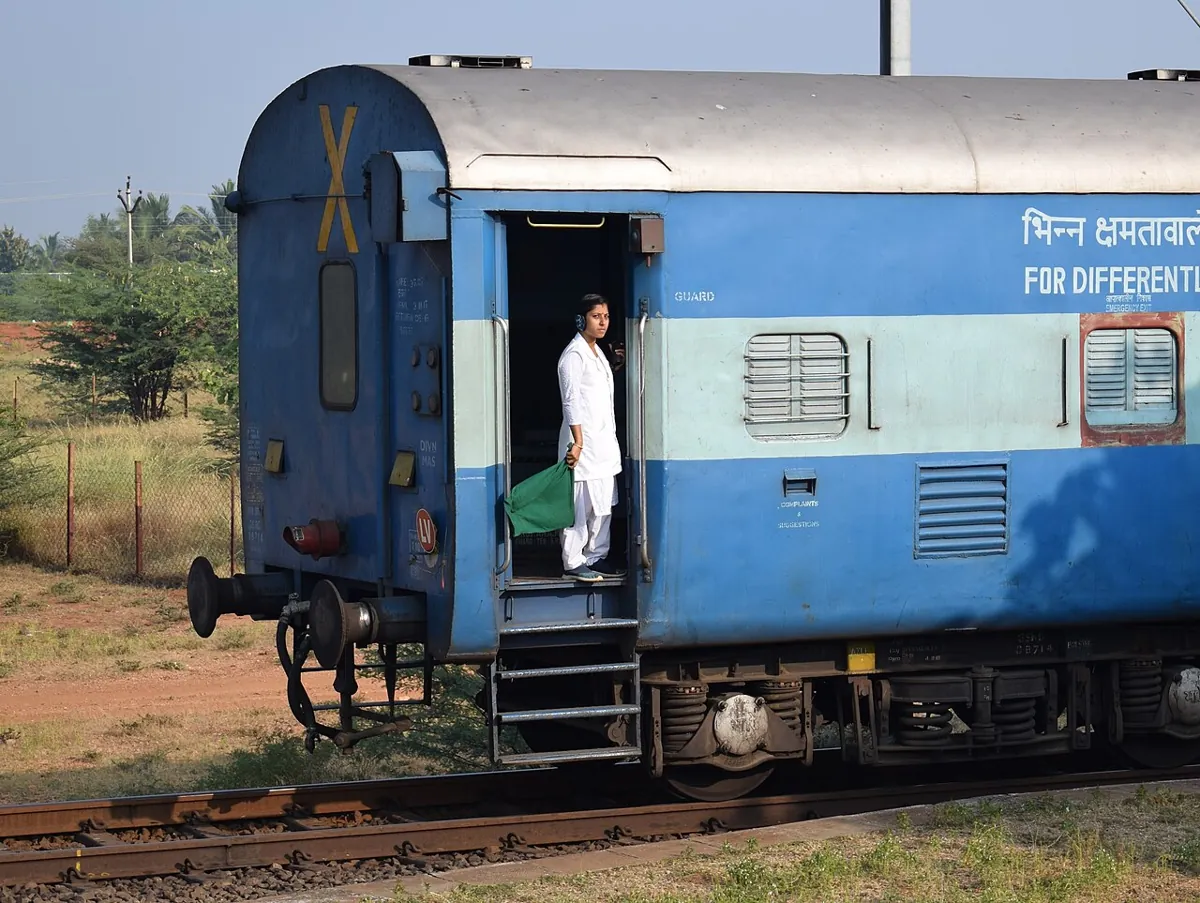
Think of a train leaving a station. The guard does not walk to every coach and start it. She checks the train, raises the green flag, and the whole train moves together. A launch file is that green flag: it describes which nodes to start, with which names, namespaces and parameters — and starts them all at once.
By the end of this lesson you will be able to: explain what the launch system does; read and write a Python launch file with Node, namespaces, parameters and remaps; write the same file in XML; add launch arguments with DeclareLaunchArgument and LaunchConfiguration; install launch files in a package; use respawn safely; and debug the usual launch errors.
Concept
How launch works
What the docs say launch is for
The Jazzy Launch concept page says a ROS 2 system usually has many nodes in many processes (even on different machines). Starting each by hand gets cumbersome quickly, so the launch system automates running many nodes with a single command. It describes what programs to run, where, with what arguments, and it monitors the processes it started and can react when they change.
| Fact from the docs | What it means for our arm |
|---|---|
| Launch files can be written in XML, YAML or Python | We show Python and XML; pick one style per project |
Run them with ros2 launch | ros2 launch arm_bringup arm_launch.py |
The package is launch_ros, built on the general launch framework | Import Node from launch_ros.actions |
A Python launch file defines generate_launch_description() returning a LaunchDescription | The whole arm is one list of actions |
Name Python files ending in launch.py so ros2 launch recognises and autocompletes them | arm_launch.py, not arm.py |
By convention, launch files sit in a launch/ folder of the package | arm_bringup/launch/ |
The official turtlesim mimic example
The Jazzy tutorial starts two turtlesim windows in different namespaces (turtlesim1, turtlesim2) so their topics do not clash, and a mimic node whose topics are remapped so turtle 2 copies turtle 1. Namespaces and remaps are the two tools you will use most.
from launch import LaunchDescription
from launch_ros.actions import Node


def generate_launch_description():
    return LaunchDescription([
        Node(
            package='turtlesim',
            namespace='turtlesim1',
            executable='turtlesim_node',
            name='sim',
            arguments=['--ros-args', '--log-level', 'info']
        ),
        Node(
            package='turtlesim',
            namespace='turtlesim2',
            executable='turtlesim_node',
            name='sim',
            ros_arguments=['--log-level', 'warn']
        ),
        Node(
            package='turtlesim',
            executable='mimic',
            name='mimic',
            remappings=[
                ('/input/pose', '/turtlesim1/turtle1/pose'),
                ('/output/cmd_vel', '/turtlesim2/turtle1/cmd_vel'),
            ]
        )
    ])
Launch arguments: one file, many robots
DeclareLaunchArgument defines an argument that can be passed from the console; LaunchConfiguration reads its value anywhere in the description. You pass values as name:=value, and ros2 launch <pkg> <file> --show-args lists them. In XML, <arg> declares and $(var name) reads.
Visual
Visualise it: one launch file, many nodes
One launch file, many nodes: change arguments and watch the node list and parameters change.
Interactive · Launch & parameter lab
ROS 2 communication simulator — educational only (not a live ros2 launch / param)


Running: none
- Launch or tweak params to see the event log.
Code lab
Code lab: a toy launcher, then the real arm launch file
launch_sim.py (plain Python, no ROS needed) “launches” our three arm nodes, changes namespace and port with arguments, restarts a crashing gripper node at most twice, and stops on a typo in an executable name. Run python3 launch_sim.py.
"""launch_sim.py - a toy "ros2 launch" (plain Python, no ROS 2 needed).

Ideas from the ROS 2 Jazzy launch docs and the launch source code:
  * one launch file describes many nodes: package, executable, name, namespace, parameters, remaps
  * launch arguments (name:=value) change the description without editing the file
  * launch watches the processes it started; respawn=True restarts a node that died,
    respawn_max_retries limits how many times
This is a teaching model, not the real launch system.
"""
INSTALLED = {
    "arm_control": {"joint_state", "gripper_service", "move_joint_server", "shoulder_angle"},
    "turtlesim": {"turtlesim_node", "mimic"},
}


def node(package, executable, name, params=None, remaps=None, respawn=False, max_retries=-1, crash_after=None):
    return dict(package=package, executable=executable, name=name, params=params or {},
                remaps=remaps or {}, respawn=respawn, max_retries=max_retries, crash_after=crash_after)


def arm_launch(args):
    """Our arm_launch.py, as plain data. args are the launch arguments."""
    ns = args.get("ns", "arm1")
    port = args.get("port", "")
    return [
        node("arm_control", "joint_state", "joint_state_node", {"rate_hz": 20.0}),
        node("arm_control", "gripper_service", "gripper_service", {}, respawn=True, max_retries=2,
             crash_after=args.get("gripper_crash_after")),
        node("arm_control", args.get("server_exec", "move_joint_server"), "move_joint_server",
             {"port": port, "start_deg": 90.0}),
    ], ns


def ros2_launch(title, args):
    print(f"\n=== ros2 launch arm_bringup arm_launch.py {' '.join(f'{k}:={v}' for k, v in args.items())} ===")
    print(f"  ({title})")
    nodes, ns = arm_launch(args)
    names = [f"/{ns}/{n['name']}" for n in nodes]
    if len(set(names)) != len(names):
        print("  WARNING: two nodes share a full name - rename or use namespaces")
    pid = 4100
    running = []
    for i, n in enumerate(nodes, 1):
        if n["executable"] not in INSTALLED.get(n["package"], set()):
            print(f"  [ERROR] [launch]: executable '{n['executable']}' not found on the libexec directory"
                  f" of package '{n['package']}' -> check console_scripts and rebuild")
            print("  launch reports the error and shuts down the nodes it already started")
            return
        pid += 1
        tag = f"{n['executable']}-{i}"
        running.append((tag, n))
        hw = f" port='{n['params']['port']}'" if "port" in n["params"] else ""
        print(f"  [INFO] [{tag}]: process started with pid [{pid}]  -> /{ns}/{n['name']}{hw}")
    # watch the processes for 10 'seconds'
    for tag, n in running:
        if n["crash_after"] is None:
            continue
        retries = 0
        t = n["crash_after"]
        while True:
            print(f"  t={t:>4.1f}s [ERROR] [{tag}]: process has died [exit code 1]")
            if not n["respawn"] or (0 <= n["max_retries"] <= retries):
                print(f"         launch gives up on {tag}; the other nodes keep running")
                break
            retries += 1
            pid += 1
            print(f"         respawn {retries}/{n['max_retries']}: [INFO] [{tag}]: process started with pid [{pid}]")
            t += n["crash_after"]
            if t > 10:
                break
    print(f"  Ctrl+C -> launch sends SIGINT to all {len(running)} processes and waits for them to exit")


print("Part 1: start the whole arm with one command (no hardware)")
ros2_launch("defaults", {})

print("\nPart 2: same file, different arguments - second arm on the real serial port")
ros2_launch("arguments change namespace and port", {"ns": "arm2", "port": "/dev/ttyACM0"})

print("\nPart 3: the gripper node crashes every 3 s (loose USB cable)")
ros2_launch("respawn=True, respawn_max_retries=2", {"gripper_crash_after": 3.0})

print("\nPart 4: a typo in the executable name")
ros2_launch("move_joint_sever instead of move_joint_server", {"server_exec": "move_joint_sever"})

print("\nPart 5: why launch? count the commands")
manual = 3 * 3  # 3 nodes x (open terminal, source install/setup.bash, ros2 run ...)
print(f"  by hand: {manual} steps in 3 terminals, easy to forget a parameter")
print("  launch : 1 command, the same every time, arguments for what changes")
Output (run with python3 launch_sim.py)
Part 1: start the whole arm with one command (no hardware)

=== ros2 launch arm_bringup arm_launch.py  ===
  (defaults)
  [INFO] [joint_state-1]: process started with pid [4101]  -> /arm1/joint_state_node
  [INFO] [gripper_service-2]: process started with pid [4102]  -> /arm1/gripper_service
  [INFO] [move_joint_server-3]: process started with pid [4103]  -> /arm1/move_joint_server port=''
  Ctrl+C -> launch sends SIGINT to all 3 processes and waits for them to exit

Part 2: same file, different arguments - second arm on the real serial port

=== ros2 launch arm_bringup arm_launch.py ns:=arm2 port:=/dev/ttyACM0 ===
  (arguments change namespace and port)
  [INFO] [joint_state-1]: process started with pid [4101]  -> /arm2/joint_state_node
  [INFO] [gripper_service-2]: process started with pid [4102]  -> /arm2/gripper_service
  [INFO] [move_joint_server-3]: process started with pid [4103]  -> /arm2/move_joint_server port='/dev/ttyACM0'
  Ctrl+C -> launch sends SIGINT to all 3 processes and waits for them to exit

Part 3: the gripper node crashes every 3 s (loose USB cable)

=== ros2 launch arm_bringup arm_launch.py gripper_crash_after:=3.0 ===
  (respawn=True, respawn_max_retries=2)
  [INFO] [joint_state-1]: process started with pid [4101]  -> /arm1/joint_state_node
  [INFO] [gripper_service-2]: process started with pid [4102]  -> /arm1/gripper_service
  [INFO] [move_joint_server-3]: process started with pid [4103]  -> /arm1/move_joint_server port=''
  t= 3.0s [ERROR] [gripper_service-2]: process has died [exit code 1]
         respawn 1/2: [INFO] [gripper_service-2]: process started with pid [4104]
  t= 6.0s [ERROR] [gripper_service-2]: process has died [exit code 1]
         respawn 2/2: [INFO] [gripper_service-2]: process started with pid [4105]
  t= 9.0s [ERROR] [gripper_service-2]: process has died [exit code 1]
         launch gives up on gripper_service-2; the other nodes keep running
  Ctrl+C -> launch sends SIGINT to all 3 processes and waits for them to exit

Part 4: a typo in the executable name

=== ros2 launch arm_bringup arm_launch.py server_exec:=move_joint_sever ===
  (move_joint_sever instead of move_joint_server)
  [INFO] [joint_state-1]: process started with pid [4101]  -> /arm1/joint_state_node
  [INFO] [gripper_service-2]: process started with pid [4102]  -> /arm1/gripper_service
  [ERROR] [launch]: executable 'move_joint_sever' not found on the libexec directory of package 'arm_control' -> check console_scripts and rebuild
  launch reports the error and shuts down the nodes it already started

Part 5: why launch? count the commands
  by hand: 9 steps in 3 terminals, easy to forget a parameter
launch : 1 command, the same every time, arguments for what changesTry it: change launch arguments and parameters and see which nodes start with which values.
Interactive · Launch & parameter lab
ROS 2 communication simulator — educational only (not a live ros2 launch / param)
Running: none
- Launch or tweak params to see the event log.
arm_launch.py — the whole arm in one file
This uses the nodes from Lessons 5–7 through the console_scripts names we gave them in Lesson 8. ns and port are launch arguments. output='screen' prints node logs in the launch terminal (the launch source says the default is log).
"""arm_launch.py - start the AIHUB desk arm with one command (ROS 2 Jazzy).

ros2 launch arm_bringup arm_launch.py
ros2 launch arm_bringup arm_launch.py ns:=arm2 port:=/dev/ttyACM0
ros2 launch arm_bringup arm_launch.py --show-args
"""
from launch import LaunchDescription
from launch.actions import DeclareLaunchArgument
from launch.substitutions import LaunchConfiguration
from launch_ros.actions import Node


def generate_launch_description():
    ns = LaunchConfiguration('ns')
    port = LaunchConfiguration('port')

    return LaunchDescription([
        DeclareLaunchArgument('ns', default_value='arm1',
                              description='Namespace for this arm'),
        DeclareLaunchArgument('port', default_value='',
                              description="Arduino serial port for the joint servo; '' = simulate"),

        # Publishes sensor_msgs/JointState (Lesson 5). Simulated: no port.
        Node(
            package='arm_control',
            executable='joint_state',
            name='joint_state_node',
            namespace=ns,
            parameters=[{'rate_hz': 20.0}],
            output='screen',
        ),
        # std_srvs/SetBool gripper (Lesson 6). Restart it if it dies, but at most twice.
        Node(
            package='arm_control',
            executable='gripper_service',
            name='gripper_service',
            namespace=ns,
            output='screen',
            respawn=True,
            respawn_delay=2.0,
            respawn_max_retries=2,
        ),
        # MoveJoint action server (Lesson 7). Only this node opens the serial port:
        # one serial port can be opened by one node at a time.
        Node(
            package='arm_control',
            executable='move_joint_server',
            name='move_joint_server',
            namespace=ns,
            parameters=[{'port': port, 'start_deg': 90.0}],
            output='screen',
        ),
    ])
The same arm in XML
<?xml version="1.0" encoding="UTF-8"?>
<!-- Same arm as arm_launch.py, written in XML.
     ros2 launch arm_bringup arm_launch.xml ns:=arm1 port:=/dev/ttyACM0 -->
<launch>
  <arg name="ns" default="arm1" description="Namespace for this arm"/>
  <arg name="port" default="" description="Arduino serial port; empty = simulate"/>

  <node pkg="arm_control" exec="joint_state" name="joint_state_node" namespace="$(var ns)" output="screen">
    <param name="rate_hz" value="20.0"/>
  </node>

  <node pkg="arm_control" exec="gripper_service" name="gripper_service" namespace="$(var ns)"
        output="screen" respawn="true" respawn_delay="2.0" respawn_max_retries="2"/>

  <node pkg="arm_control" exec="move_joint_server" name="move_joint_server" namespace="$(var ns)" output="screen">
    <param name="port" value="$(var port)"/>
    <param name="start_deg" value="90.0"/>
  </node>
</launch>
Install the launch files with the package
The Jazzy “Integrating launch files into ROS 2 packages” tutorial adds the launch/ folder to data_files in setup.py (for CMake packages: install(DIRECTORY launch DESTINATION share/${PROJECT_NAME})). The “Creating a launch file” tutorial also recommends <exec_depend>ros2launch</exec_depend> in package.xml.
# arm_bringup/setup.py - install every file in launch/ (from the Jazzy
# "Integrating launch files into ROS 2 packages" tutorial)
import os
from glob import glob
from setuptools import find_packages, setup

package_name = 'arm_bringup'

setup(
    name=package_name,
    # ...
    data_files=[
        ('share/ament_index/resource_index/packages', ['resource/' + package_name]),
        ('share/' + package_name, ['package.xml']),
        (os.path.join('share', package_name, 'launch'), glob('launch/*')),
    ],
    # ...
)

# arm_bringup/package.xml - add:
#   <exec_depend>ros2launch</exec_depend>
# <exec_depend>arm_control</exec_depend>cd ~/arm_ws
colcon build --symlink-install
# new terminal
source install/setup.bash
ros2 launch arm_bringup arm_launch.py --show-args
ros2 launch arm_bringup arm_launch.py # simulate, /arm1
ros2 launch arm_bringup arm_launch.py ns:=arm2 port:=/dev/ttyACM0
# in another terminal, check what started
ros2 node list
ros2 run rqt_graph rqt_graphReal world
Launch files in the real world
- turtlesim mimic (official tutorial): two simulators and a mimic node from one file, using namespaces and remaps.
- Robot arms: a “bringup” launch file starts drivers, state publishers and controllers; a second one adds planning or vision.
- Many robots, one file: warehouses run the same launch file with a different namespace argument on every robot.
- Labs and classrooms: a launch file is the lab manual in code — every student starts the same system the same way.
Bench build
Bench build: start the bench arm with one command
Same one-servo bench as Lessons 7–8 with servo_position.ino. This time nothing is started by hand: one ros2 launch brings up joint states, the gripper service (simulated) and the move-joint server on the real port.
| From | To | Note |
|---|---|---|
| Servo signal | Arduino D9 | Signal only |
| Servo + (red) | Separate 5–6 V supply + | Not the Arduino 5V pin or any GPIO |
| Servo − (brown/black) | Supply − | — |
| Supply − | Arduino GND | Common ground |
| Arduino USB | ROS 2 computer | 115200 baud |
// servo_position.ino - one servo follows position commands "P<deg>" (e.g. P93.5) at up to ~50 Hz.
// Used by move_joint_server.py, which does the smooth cubic profile on the computer.
// Clamps to 10..170 deg and uses writeMicroseconds for finer steps than whole degrees.
// With no new commands the servo simply holds its last position.
// POWER: servo red (+) to a SEPARATE 5-6 V supply, never the Arduino 5V pin or a GPIO. Join grounds.
#include <Servo.h>

const int SERVO_PIN = 9;
const float MIN_DEG = 10.0, MAX_DEG = 170.0;
Servo joint;
char buf[16];
byte n = 0;

int degToUs(float d) { return (int)(544.0 + (2400.0 - 544.0) * d / 180.0); }  // Servo library default range

void setup() {
  Serial.begin(115200);
  joint.attach(SERVO_PIN);
  joint.writeMicroseconds(degToUs(90.0));
}

void loop() {
  while (Serial.available()) {
    char c = Serial.read();
    if (c == '\n') {
      buf[n] = 0;
      if (n > 1 && buf[0] == 'P') {
        float d = atof(buf + 1);
        if (d < MIN_DEG) d = MIN_DEG;
        if (d > MAX_DEG) d = MAX_DEG;
        joint.writeMicroseconds(degToUs(d));
      }
      n = 0;
    } else if (n < sizeof(buf) - 1) {
      buf[n++] = c;
    }
  }
}Dry run
Servo supply off.
ros2 launch arm_bringup arm_launch.py— three nodes should start in/arm1, all simulated.Check the graph
ros2 node listandros2 action list -t; you should see/arm1/move_joint.Real port
Stop with Ctrl+C. Switch the servo supply on.
ros2 launch arm_bringup arm_launch.py port:=/dev/ttyACM0Move slowly
ros2 action send_goal /arm1/move_joint arm_interfaces/action/MoveJoint "{target_deg: 60.0, duration_s: 3.0}" --feedbackShut down
Ctrl+C in the launch terminal stops every node it started. Then switch the servo supply off.
Debugging
Debugging launch files
| Symptom | Likely cause | Fix |
|---|---|---|
file 'arm_launch.py' was not found in the share directory | Launch folder not in data_files, or not rebuilt | Add the glob('launch/*') line, rebuild, re-source |
executable … not found | Wrong executable= or missing console_scripts | ros2 pkg executables arm_control and copy the name |
| Two nodes fight over the same topic | Same name/namespace for two arms | Use the ns argument or a namespace= |
| Argument ignored | Typo in name:=value or argument not declared | --show-args lists what the file accepts |
| No node logs in the terminal | Output goes to the log by default | Add output='screen' |
| “Could not open port” in one node | Two nodes were given the same serial port | Give the port to one node only |
| A node restarts forever | respawn=True with no limit | Set respawn_max_retries and fix the crash |
Think
Think about it
Think
Your arm’s move-joint node crashes because the USB cable is loose. Should launch respawn it automatically? What could go wrong, and what would you do instead?
Experiment
Try it in the lab
About 40 minutes with Python; the ROS 2 steps need ROS 2 Jazzy with turtlesim and your arm_ws from Lesson 8; the bench step needs the Lesson 7 servo build.
Experiment
One command for the whole arm
You will need
- `launch_sim.py` and Python 3
- Launch & parameter lab (in your browser)
- Optional: ROS 2 Jazzy, turtlesim, `arm_ws`, Arduino UNO, hobby servo, separate 5–6 V supply
Steps
- Run `launch_sim.py`. In Part 3 change `max_retries` to 0 and to -1. What changes, and why is -1 risky?
- Add a fourth node `shoulder_angle` to `arm_launch()` in the simulator. Give it the same port as the server — what would happen on a real robot?
- With ROS 2: save the turtlesim mimic launch file, run it, and publish to `/turtlesim1/turtle1/cmd_vel` as in the tutorial. Both turtles should move.
- With ROS 2: add `arm_launch.py` to `arm_bringup`, build, and run with `--show-args`, then with `ns:=arm2`.
- With ROS 2: run the XML version and compare `ros2 node list` with the Python version.
- Bench: launch with the real port and send a slow goal.
Interactive · Launch & parameter lab
ROS 2 communication simulator — educational only (not a live ros2 launch / param)
Running: none
- Launch or tweak params to see the event log.
Launch turns a page of terminal commands into one repeatable command. Arguments handle what changes between robots; namespaces keep them apart.
Knowledge check
Check your understanding
Knowledge check
1. What is the launch system for?
2. Which formats can ROS 2 launch files use?
3. A Python launch file must define…
4. In the mimic example, why are the two turtlesim nodes in different namespaces?
5. How do you pass a launch argument from the terminal?
6. `ros2 launch arm_bringup arm_launch.py` says the file is not found. Most likely?
7. Which node is safest to respawn automatically?
Mini assignment
Hands-on assignment
Mini assignment
A bringup launch file for your 6DOF arm
Write the launch file that starts your arm’s software, with arguments for what changes between robots.
Deliverables
- A table of every node your arm needs: package, executable, name, namespace, parameters, and whether it may respawn (with a reason).
- Output of `launch_sim.py` after your experiment changes.
- Optional (ROS 2): your `arm_launch.py`, the output of `--show-args`, and `ros2 node list` while it runs.
- Optional (bench): a short video of the servo moving after a single `ros2 launch` command.
Do this, step by step
- Run
python3 launch_sim.pyand trymax_retries0 and -1; write what changes. - Make a table of every node your arm needs: package, executable, name, namespace, parameters, respawn yes/no with reason.
- Add the
shoulder_anglenode with the same port as the server and write what would happen on a real robot. - Optional with ROS 2: add
arm_launch.pytoarm_bringup, build, and run with--show-argsand withns:=arm2. - Compare
ros2 node listfor the Python and XML launch versions.
Stuck? Hints, one at a time
- Two nodes cannot hold one serial port at the same time — the second one fails to open it.
- Endless respawn hides a crash loop; a driver that keeps crashing should stop and be looked at.
- Launch arguments are for what changes between robots (namespace, port); keep everything else fixed.
Challenges (pick by level)
- 🟢 Easy: Run the turtlesim mimic example in all three formats (XML, YAML, Python).
- 🟡 Medium: Add a
use_hwargument that sets the server’s port only when true. - 🟠 Hard-ish: Write a second launch file that includes
arm_launch.pytwice for/arm1and/arm2(look upIncludeLaunchDescription). - 🔴 Hard: Add a
TimerActionthat starts the move-joint server 3 s after the others and explain when a delay like that helps. - ⚫ Research: Read the ROS 2 launch design article and list which planned features exist in Jazzy and which do not yet.
Next step
Our launch file already passes rate_hz, port and start_deg. In Lesson 10 — Parameters & Configuration you will learn how parameters really work, change them while nodes run, and keep them in YAML files.
Look back: Lesson 8: ROS 2 Packages & Workspace. Next: Lesson 10: Parameters & Configuration. Related: Stage 3 — Linux & Dev Environment.
Sources
- ROS 2 Jazzy docs — Launch (concepts) — many nodes with one command, configuration, monitoring, XML/YAML/Python,
ros2 launch. - ROS 2 Jazzy docs — Creating a launch file —
launch_ros, turtlesim mimic example, namespaces, remaps,argsvsros_args,exec_depend ros2launch, process-started output. - ROS 2 Jazzy docs — Integrating launch files into ROS 2 packages —
launch/folder,data_fileswithglob, CMakeinstall(DIRECTORY …),launch.pysuffix,generate_launch_description(). - ROS 2 Jazzy docs — Using substitutions —
DeclareLaunchArgument,LaunchConfiguration,$(var …),--show-args,name:=value. - ros2/launch (jazzy) — execute_process.py —
outputdefaultlog,respawn,respawn_delay,respawn_max_retries(negative = forever). - ros2/launch_ros (jazzy) — node.py —
Nodeparameters, XMLpkg/exec/namespace/param. - Docs text read from the official docs source ros2/ros2_documentation (jazzy branch).
- Photos: Wikimedia Commons (credits under each image).
Self-attested for now — keep artifacts in your lab notebook.
Complete
Today's goal
0 of 1 done today
Mark this lesson complete when you have worked the experiment, knowledge check, and assignment (even roughly).